Computer vision · 3D perception
3D hand & object tracking
An end-to-end workflow for estimating 3D hand and object poses from multi-camera recordings at UT Dallas.
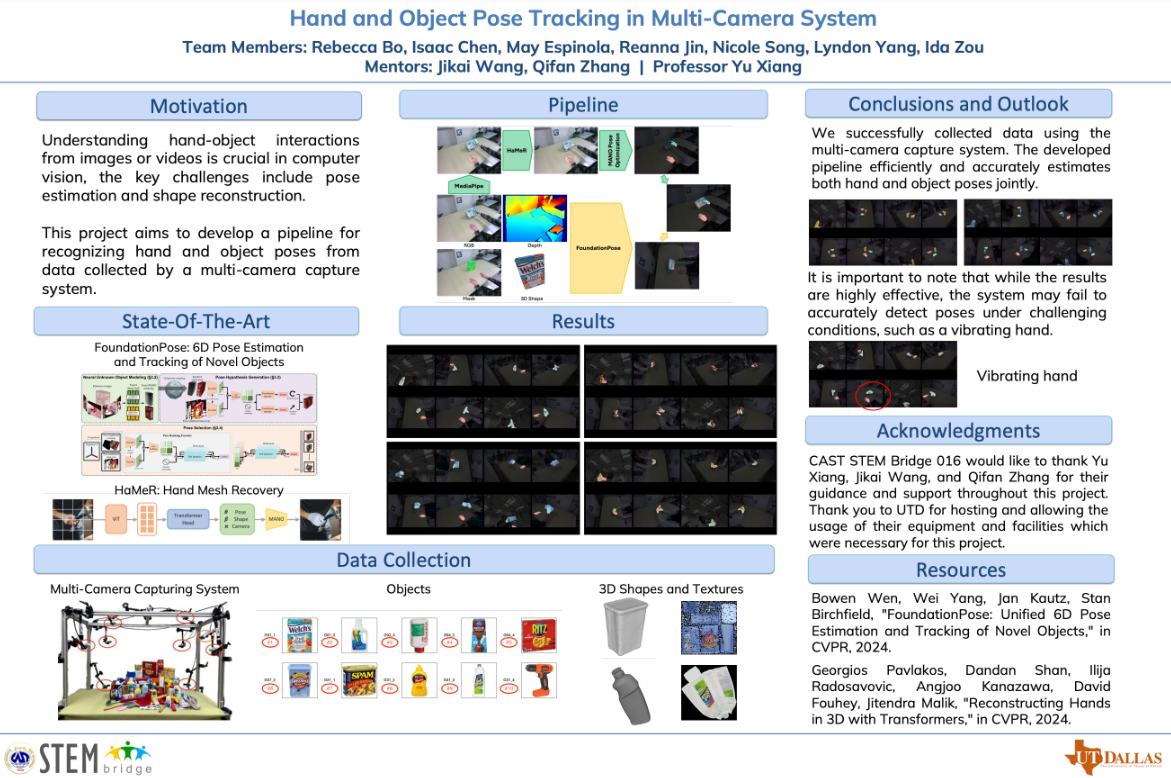
Research image from my UT Dallas project
Seeing an interaction in 3D
A hand interacting with an object changes shape, moves through space, and hides parts of the scene. Reconstructing both hand and object poses is useful for studying manipulation and spatial interaction.
My contribution
I spent two months developing a pose-estimation pipeline using a multi-camera system. My work included MANO hand-shape modeling, HaMeR hand-mesh recovery, and FoundationPose object-pose estimation.
The workflow
The project connects camera-based data collection with processing and pose estimation. It brings hand and object information into one workflow rather than treating the two independently.
Outcome
The work received second place at the UT Dallas STEM Research Competition in 2024. It helped establish the perception foundation for my later work in robot learning and manipulation.