01 ✧

Perceiving & interacting

Robots that understand the world around them.

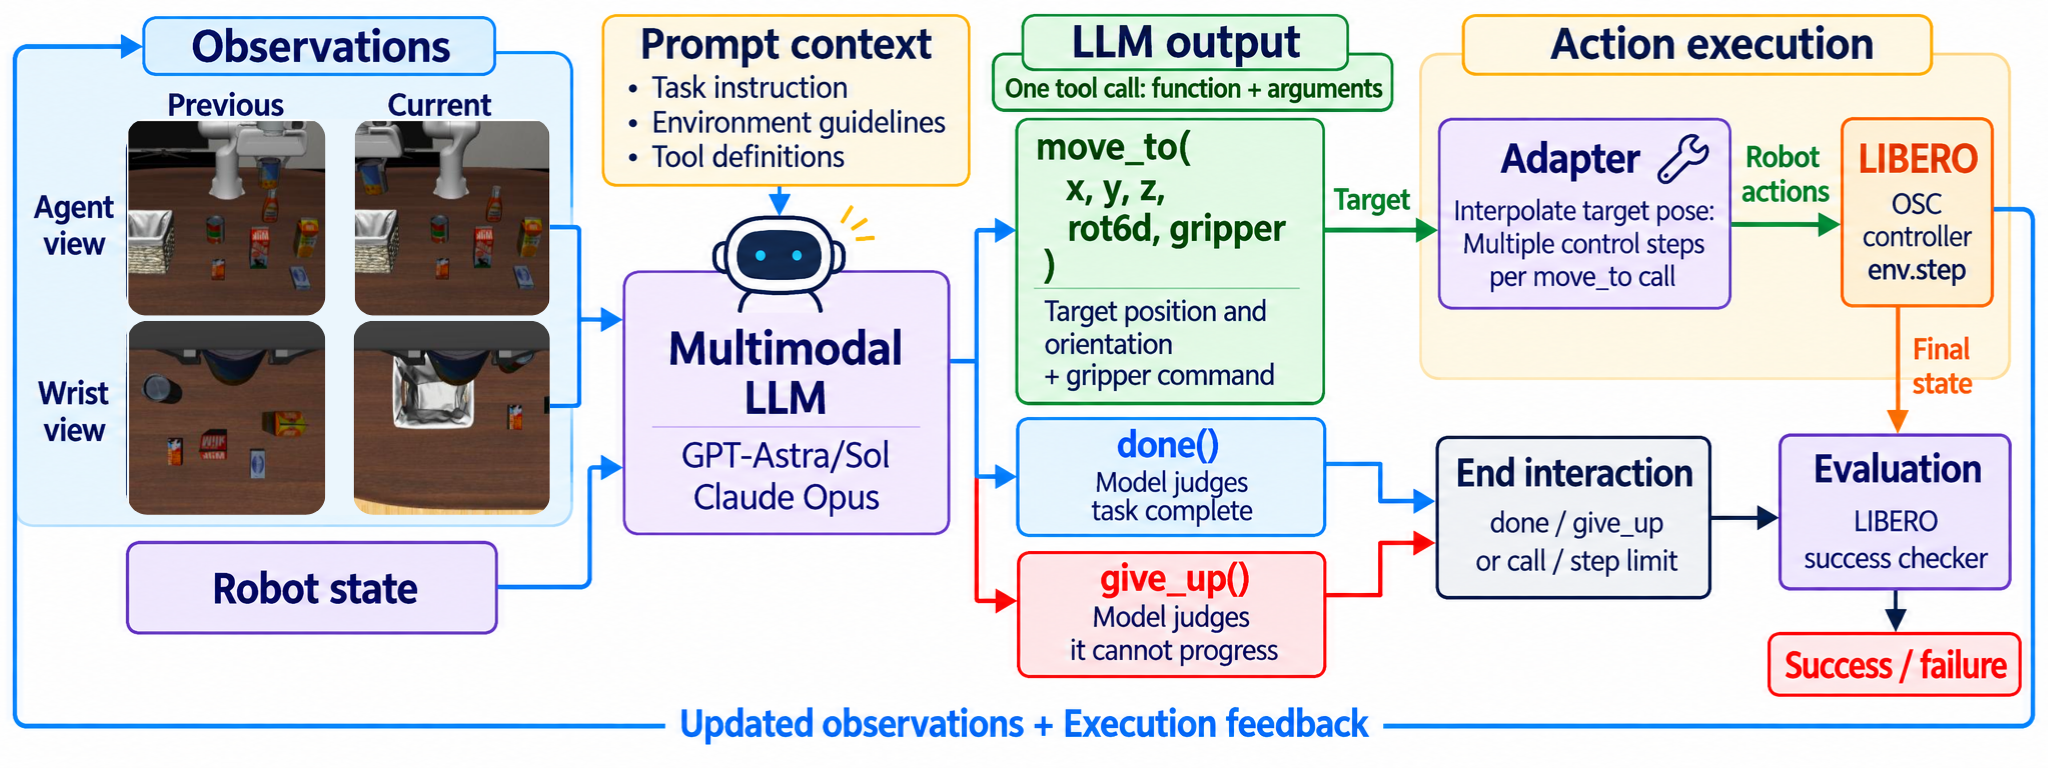
LLM-LIBERO evaluation loop: camera observations and robot state inform a multimodal language model, which selects robot actions evaluated in LIBERO.

Current · IRVL, UT Dallas · Equal contribution

From Reasoning to Action: LLM-LIBERO

What it isBenchmarking frontier AI models on LIBERO-10 robot manipulation tasks. Models use camera observations and robot state to choose actions in a closed loop, connecting language-model reasoning to robot control.

Explore interactive results comparing task success, cost, and API calls, with rollout videos and 3D spatial plans for individual episodes.

Robot Manipulation Multimodal LLMs LIBERO-10 Evaluation
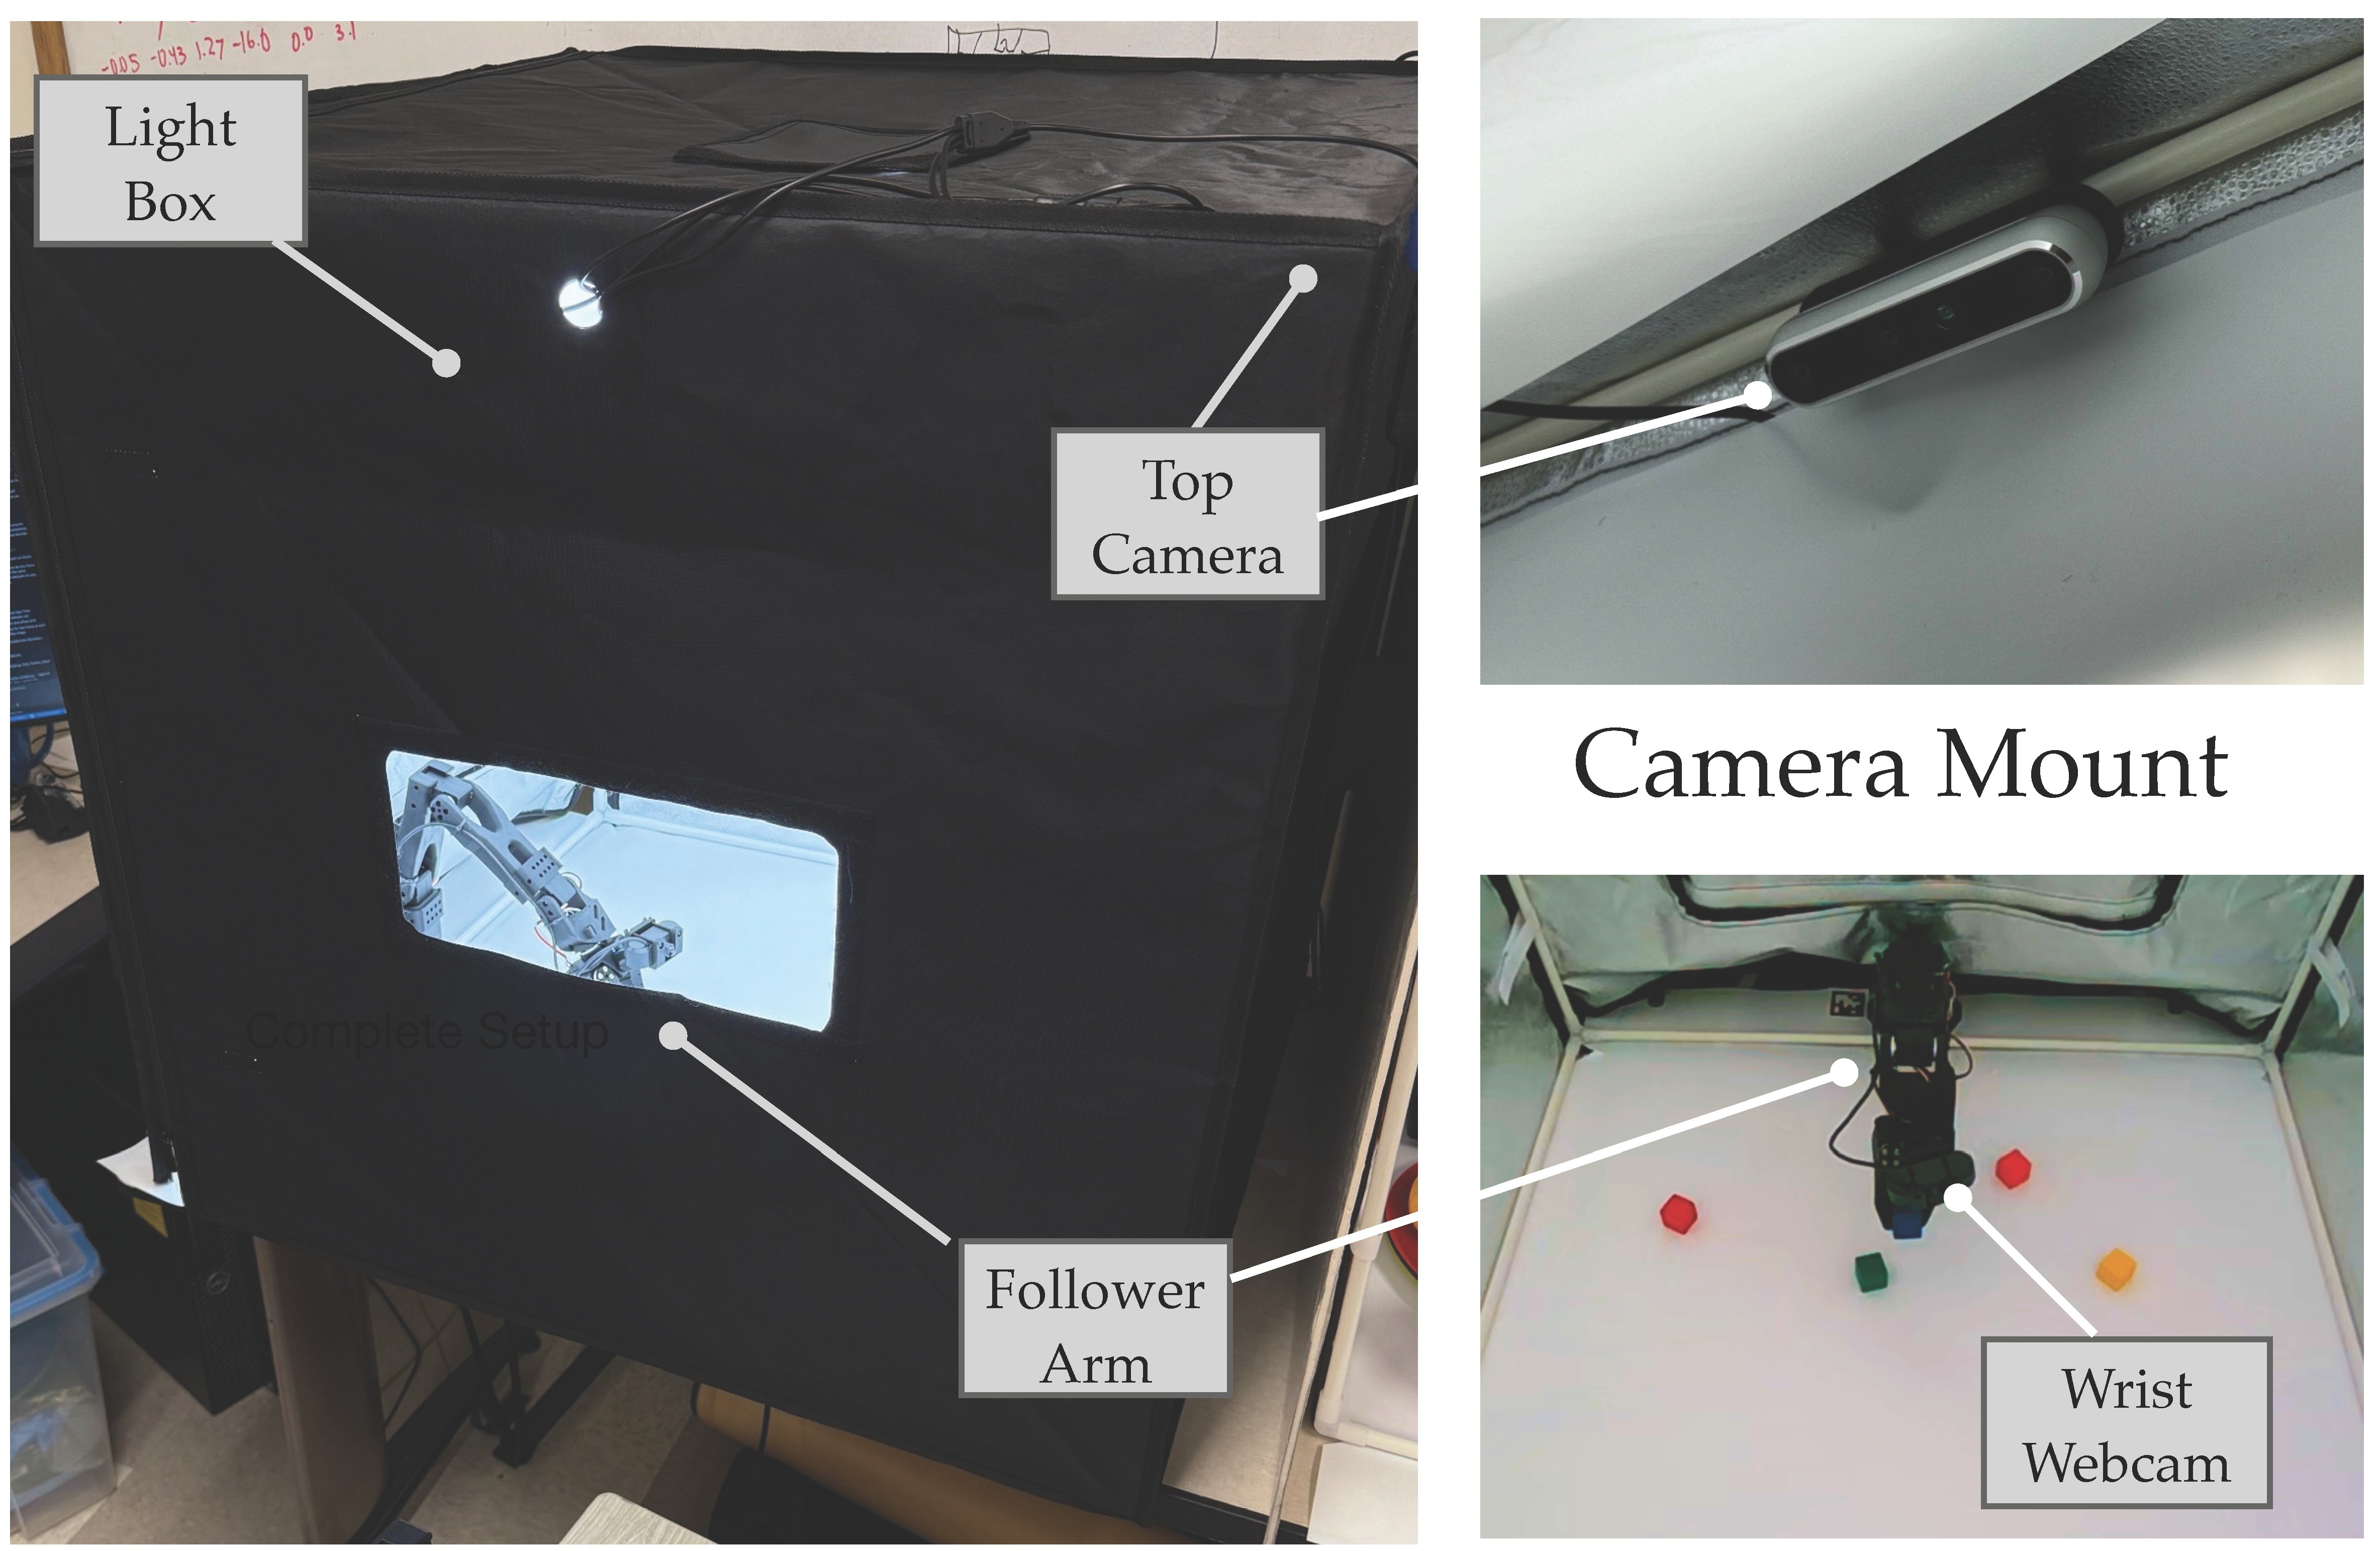
RobotReplica SO-101 evaluation workspace
Partner Labs

IRVL @ UT Dallas
General Intelligence Labs (CA)
GRILL @ Cornell
CDFG + Persci @ MIT
PRACTICE @ UCLA
IRIS @ ASU
GRASP @ Penn

Current · IRVL, UT Dallas

RobotReplica

What it isA shared network of physical robot benchmarks: researchers send a policy to a site with matching hardware, where it is tested on a real robot and returned as a verified, comparable result.

Maintainer of the UT Dallas SO-101 site for VLA-Replica manipulation evaluations & fine-tuned new evaluations.

02 ✧

Regeneron ISEF projects

International Science and Engineering Fair (ISEF) is the world’s largest pre-college science and engineering competition. Millions of students begin at local science fairs and advance through regional, state, and national levels. Less than 1% reach the international fair—representing 60+ countries and territories to compete for $9M+ in awards and prizes.

Certificate of Special Congressional Recognition · U.S. Congressman Troy Nehls, for representing Texas at ISEF and for accessibility-focused AI work serving Deaf and Blind communities in my own community.

Safe Hands cover art showing a human hand reaching toward a robotic handISEF 2026

SFTD021 · International Science and Engineering Fair '26
Sponsored by Microsoft

Safe Hands: Object-Centric Learning for Robot Manipulation

Robotic manipulation in laboratory, industrial, and remote environments is challenging because objects vary. This project explores object-centered learning to help robot policies focus on what they need to grasp and move.

WAVE cover art for the real-time focused sign language translation projectISEF 2025

TECA018 · International Science and Engineering Fair '25
Sponsored by Midjourney

WAVE: Real-Time Focused Sign Language Translation System

A real-time, centered sign-language recognition system designed to keep attention on the person signing. It combines computer vision, hand-motion understanding, and transformer-based methods to support clearer communication.

03 ✧

Access & independence

Technology for people.

HALO predictive safety system at HackMIT 2026

HackMIT '26: HALO - Hazard Awareness for Line Out-of-sight

A predictive safety and attention system for people walking or riding micromobility vehicles. HALO uses an iPhone camera and IMU stream to detect hazards, estimate future paths, reason about collisions, and deliver directional alerts.

Computer Vision YOLO11n BoT-SORT ByteTrack EKF iPhone Camera + IMU
Audemy logo

Audemy

As a developer, I collaboratively integrated AI features into math games for the world’s largest educational game platform for blind children, reaching over 200,000 blind and visually impaired players worldwide, including 1 in 5 blind children in the U.S. On the Forbes 2026 Games list.

Python HTML CSS Flask OpenAI API
mit app inventor logo

MIT AI2 App of the Month '22: Homework App

The app streamlines homework tracking by extracting each student’s assignments from a shared spreadsheet and displaying them in a clean interface. It improves privacy and usability by eliminating the need to scroll through a class-wide list with added security.

MIT App Inventor Google API
04 ✧

NASA Space Apps Challenge

A global NASA hackathon where teams use open Earth and space data to solve practical problems. These projects moved from a Houston win into global judging and recognition.

NASA project NASA project NASA project

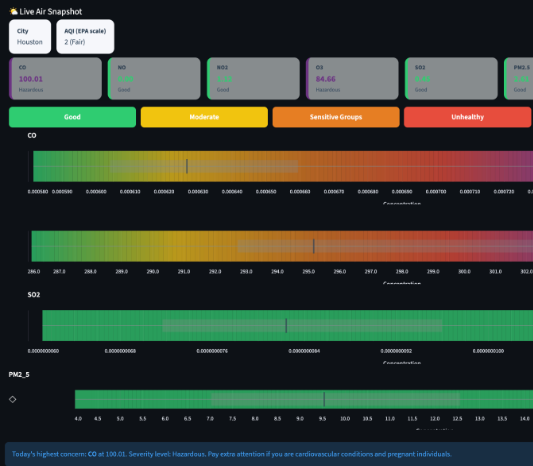
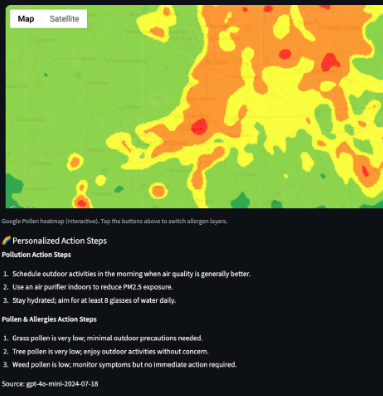
Global NASA Space Apps Challenge 25': kaleidoscope

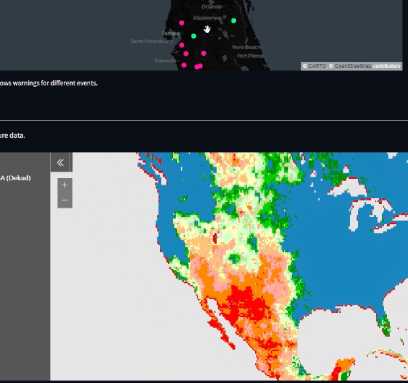
Predict, visualize, and interpret air quality using NASA and open environmental data, making atmospheric science actionable for people. Personalized action steps based on health conditions and personal risk levels, with community clean air initiative outreach.

OpenAQ API Google Air Quality API NASA MERRA-2 Fetcher OpenAI API CSS Pollen API Python Javascript KNN classification Streamlit NASA Earthdata
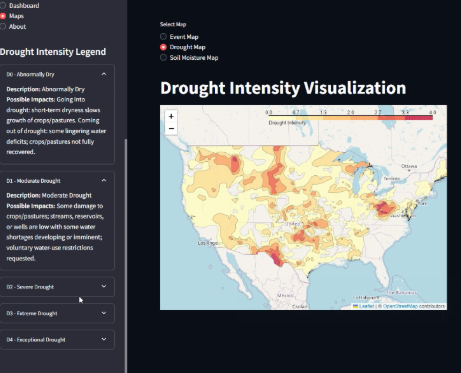
Farmvis interface farmvis demo

Global NASA Space Apps Challenge 24': Farmvis

AI GIS uses various NASA Earth observation data for actionable insights for farmers, real-time visualization of soil moisture, drought, flooding, and climate risks tailored to each farm.

Spatial clustering Outlier Detection intuitive maps Python OpenAI API Streamlit Geopy Spatial Clustering (DBSCAN) Polygon Simplification (Douglas-Peucker)
NASA project NASA project NASA project

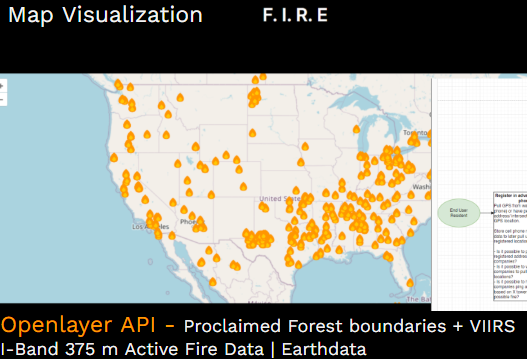
Global NASA Space Apps Challenge 23': F.I.R.E

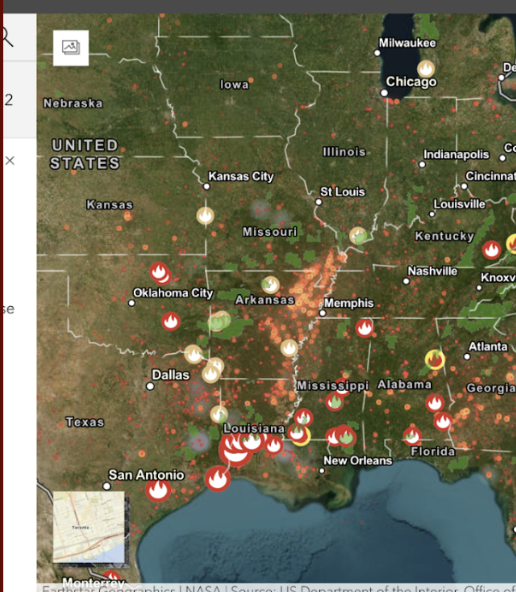
Aggregates real-time wildfire data to identify hotspots, assess risks to forests/nearby communities, and Wireless Emergency Alerts with live fire maps for guidance route.

FIRMS/USFS hotspot - active fire data Weather API wind data NOAA fire data React TypeScript TailwindCSS
05 ✧

Research scholarships

Selected summer research programs and mentorship experiences.

SMU project SMU project SMU project

Governor's Science & Technology Champion Academy 25'

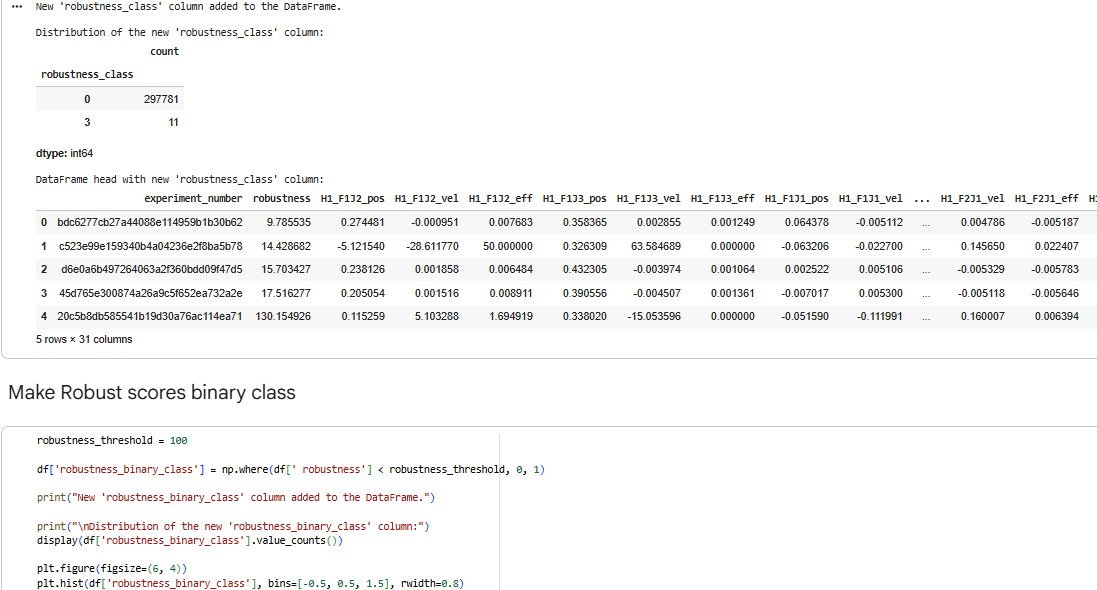
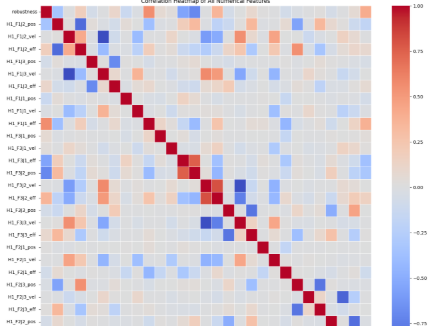
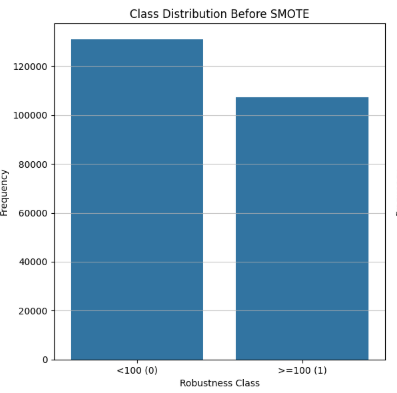
ML research under SMU Postdoc Dr. Inam Khan on anomaly detection; built meta-classifier for robotic e-waste grasping

Python Stacking (ensemble) Random Forest Decision Tree XGBoost Regression Binary Classificaton Data Analytics & Preprocessing Feature Engineering
UTD project UTD project UTD project

UT Dallas STEM-CAST Program Summer Research '24

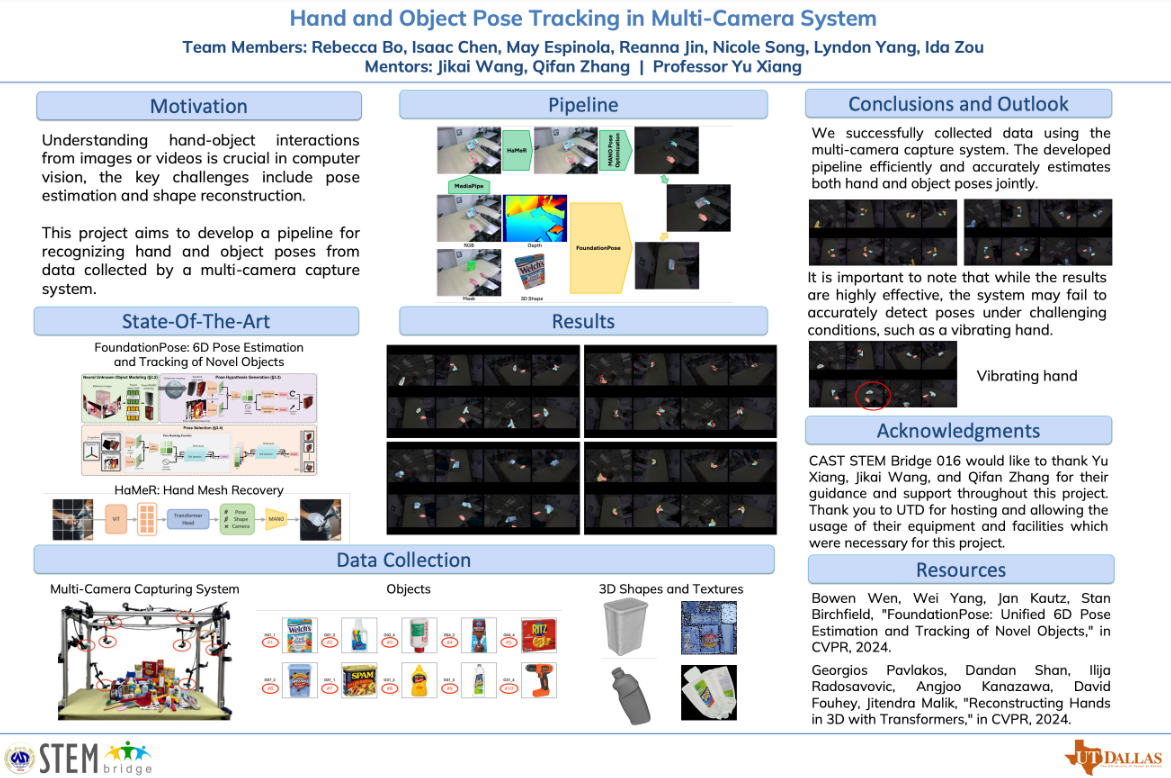
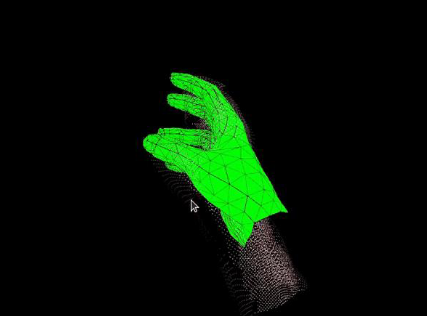
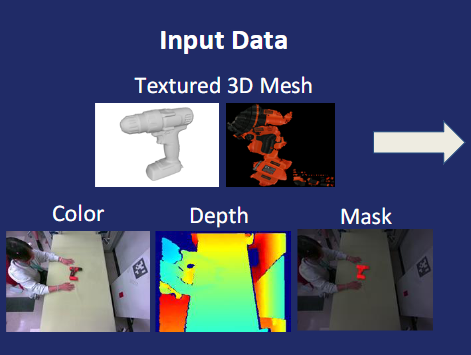
Estimate hand and object poses from data collected in a multi-camera system. Developed an end-to-end pipeline for simultaneously tracking hand and object poses from collected recordings as commonly used in AR/VR (XR), robotic and computer vision, security, etc.

Multi-Camera Systems Python 6D Pose Estimation PyTorch Data Analytics & Preprocessing RGBD Imaging MANO HaMeR Hand Mesh Recovery FoundationPose